Formula Student / embedded firmware & data
Sep 2025 – presentN7 Racing
Formula Student electric car. I lead the DATA pole, eleven engineers working on acquisition, calibration, CAN and diagnostics, including testing during the team's first successful roll. I write STM32H753 firmware in C and develop CAN Lab, the desktop tool in which we edit, compile and flash that firmware onto NUCLEO boards, then run it against simulated CAN traffic before it reaches the car.
My contribution
- DATA pole leadIn the pole since September 2025 and lead since May 2026: eleven engineers on acquisition, calibration, CAN and diagnostics, and testing during the first successful roll.
- STM32 firmwareC on STM32H753: CAN and CAN-FD, acquisition, timeouts and diagnostics, with interfaces to the NXP S32K358 BMS, the Continental gVCU and the inverter.
- CAN LabA desktop tool, Rust core and TypeScript interface, that takes the C firmware from the editor to a board and tests it against simulated vehicle traffic.
CAN Lab
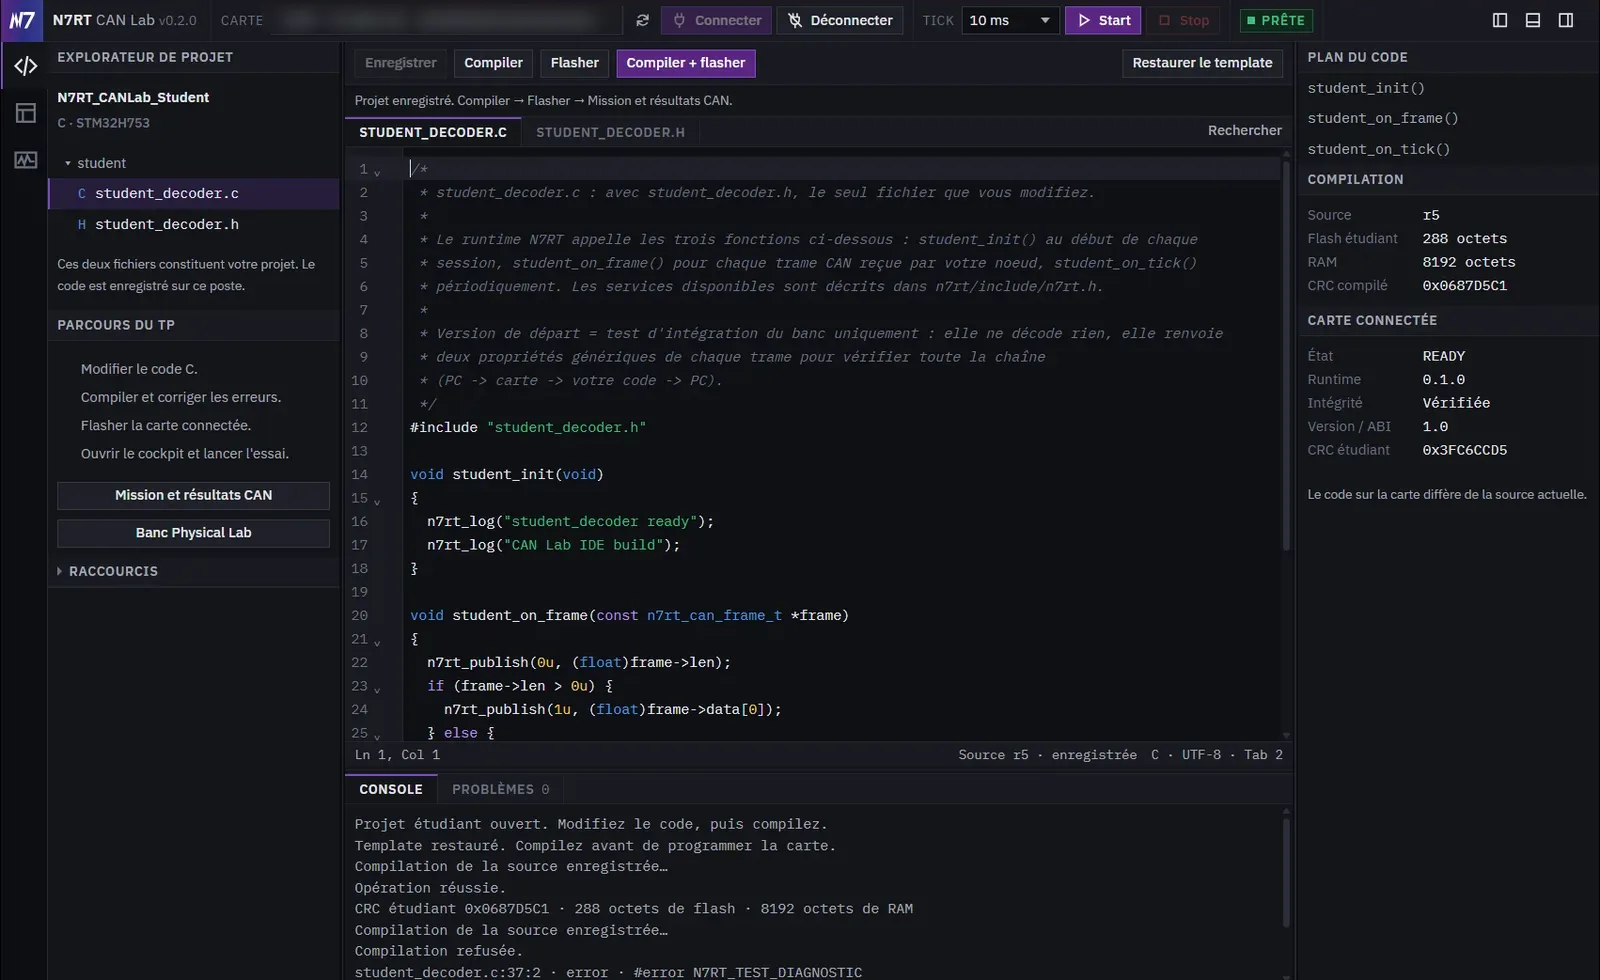
The firmware is written in C; CAN Lab itself is a desktop application. With its current version we write the firmware module, compile it, flash it onto three NUCLEO-H753ZI boards and simulate the vehicle around it.
- Edit and buildC editor for the firmware module, compiled with arm-none-eabi-gcc for the Cortex-M7 against a validated runtime and a fixed linker script.
- FlashSTM32CubeProgrammer over ST-LINK SWD writes only the application region and checks the runtime hash before and after.
- SimulateVirtual ECUs: a training ECU, and a synthetic vehicle bus with pedal, wheel-speed, steering and brake-pressure sensor ECUs plus VCU, inverter, BMS, dashboard and logger nodes.
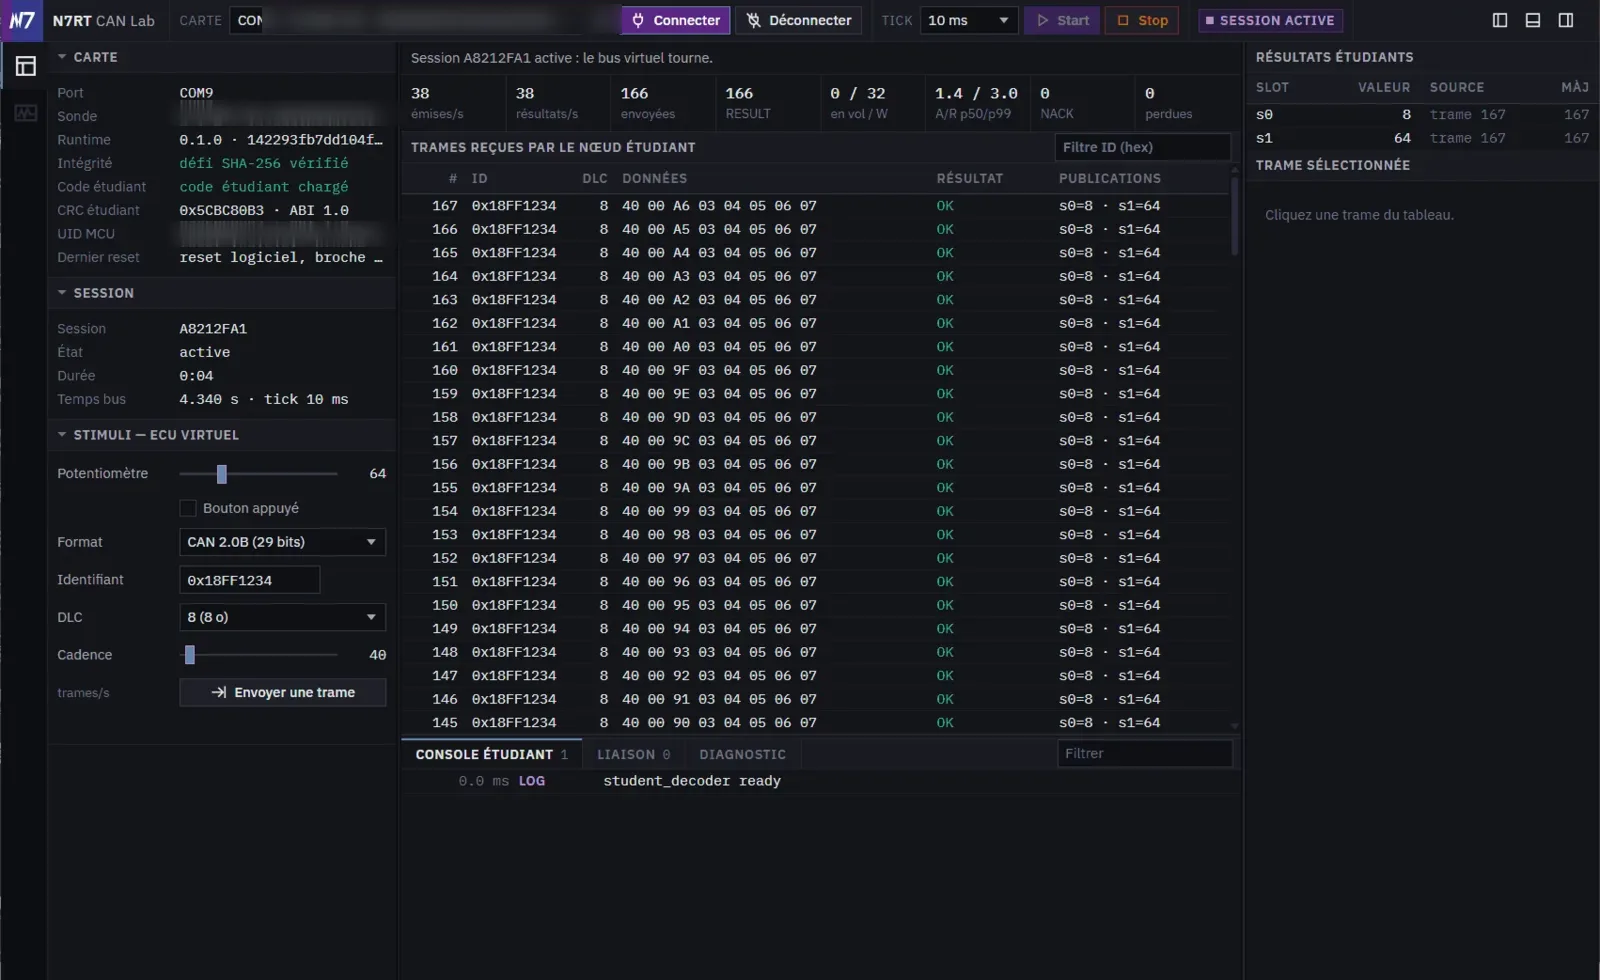
- ObserveA cockpit with the frame table, published values, link and diagnostic views, round-trip and loss metrics, and detection of stalls and fault reports.
- Circuit labA nodal-analysis solver with transient simulation for sensor, transceiver and termination circuits.
Bench results
NUCLEO-H753ZI · 5 October 2026
- Throughput
- 600 frames/s for five minutes: 180,106 frames sent and 180,106 results returned, with no loss or link error.
- Round trip
- p99 6.2 ms between the application and the board.
- Display latency
- Stimulus to displayed value: p95 67 ms.
- Link
- Simulated CAN frames over the ST-LINK serial link, not a physical CAN bus.
Vehicle network
On the car, the Continental gVCU sits at the centre of the CAN network with the inverter, the BMS on an NXP S32K358 with CAN-FD, the data logger and the dashboard. CAN Lab is not wired to that network: a bench of two NUCLEO boards with CAN transceivers will carry its frames onto a real bus.
Physical CAN bench: in progress
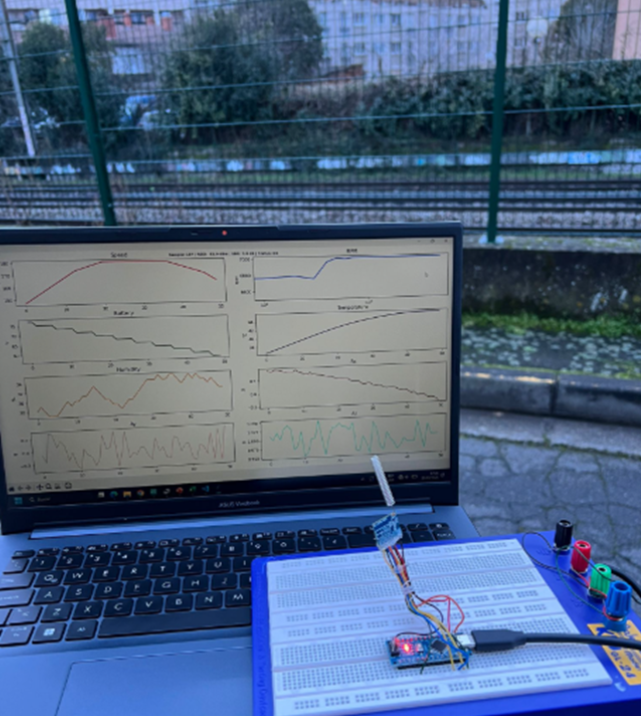
Car-to-pit LoRa telemetry was tested on a breadboard; range and packet-loss results are not published.
Electric kart retrofit
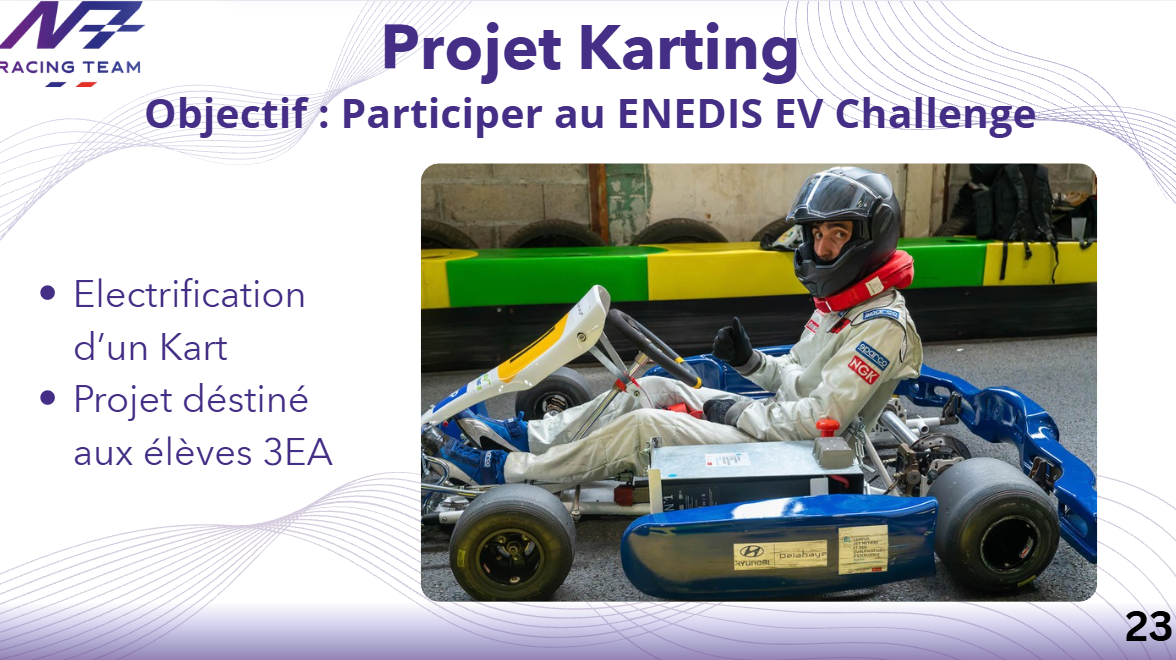
We retrofitted a kart to electric drive, a project for 3EA students aimed at the ENEDIS EV Challenge. It is separate from the Formula Student car.